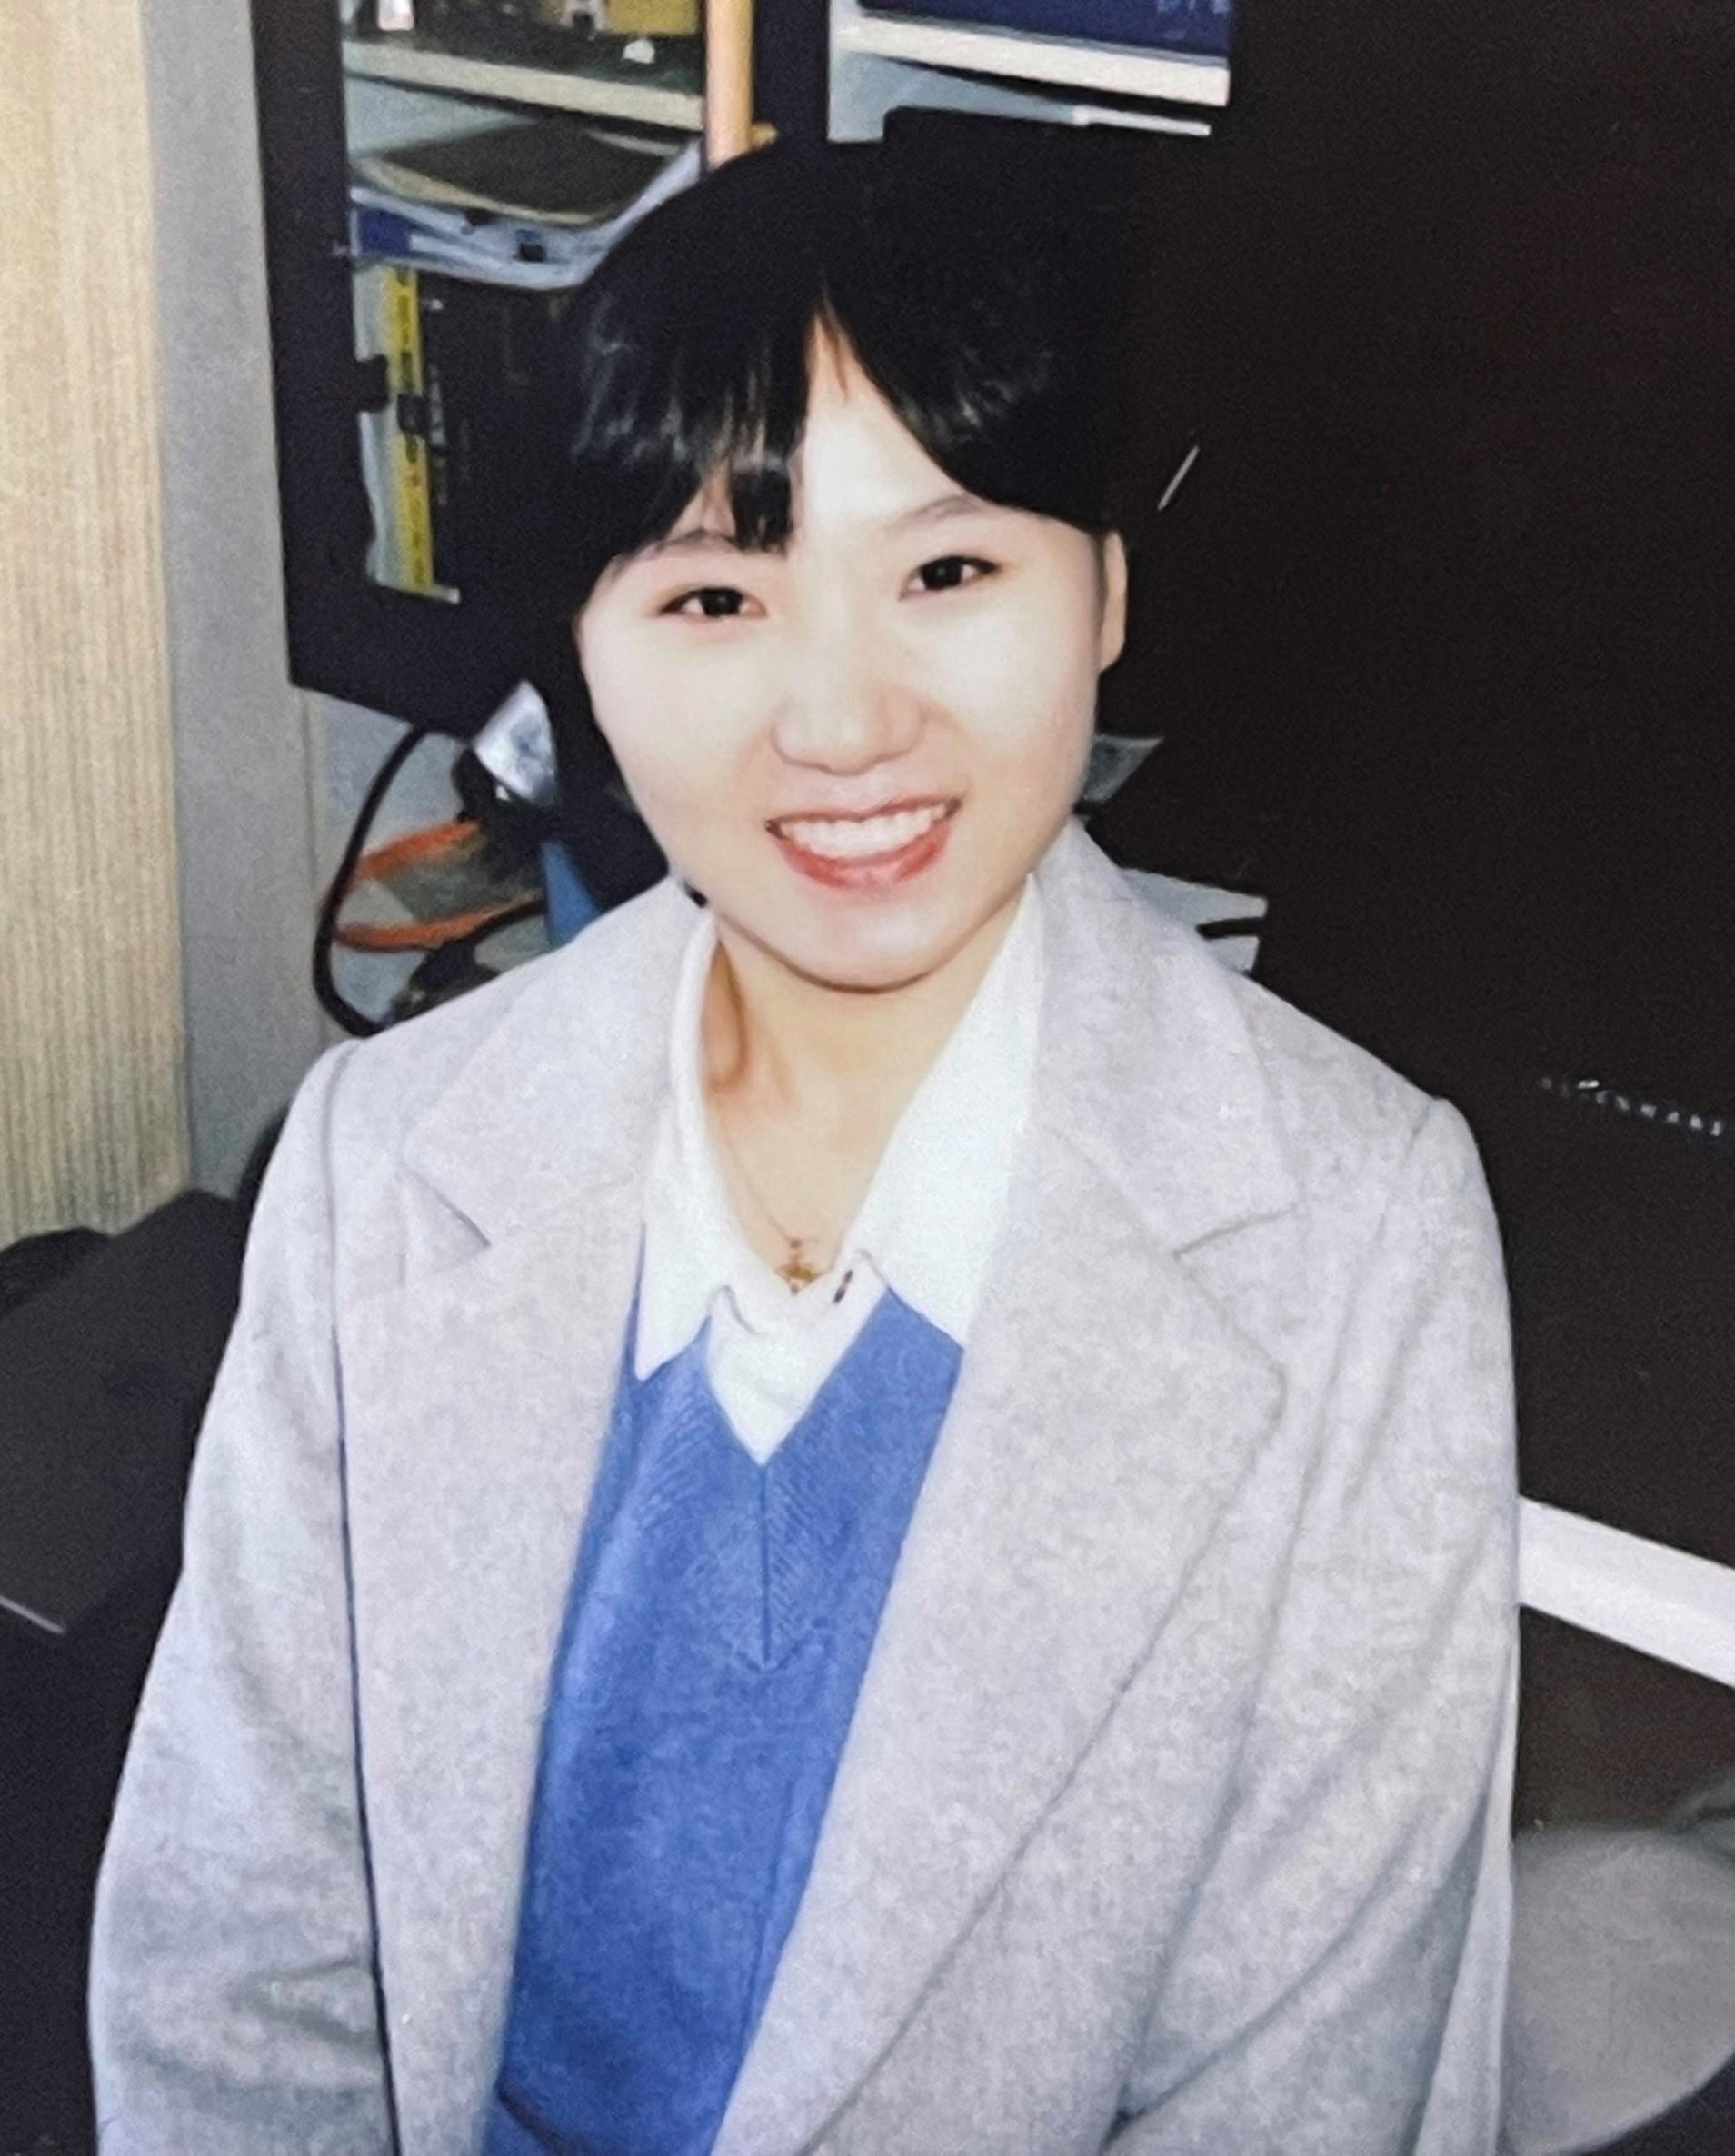
Sitong Zhang
postdoc · aalto university · espoo, finland
Hi — I’m Sitong Zhang, a Postdoctoral Researcher at Aalto University, Department of Computer Science, working with Prof. Bo Zhao.
Before Aalto I was a Postdoctoral Researcher at CityU-Oxford Joint CIMDA, City University of Hong Kong, working with Prof. Hong Yan (IEEE Fellow). I received my PhD (2023) and BEng (2018) from Harbin Engineering University, advised by Prof. Yibing Li.
Research Interests
My research lies at the intersection of machine learning and systems. I currently focus on infrastructure for distributed reinforcement learning and LLM post-training, with particular interest in the runtime designs that make these workloads fast, adaptive, and cost-aware at cluster scale.
This builds on my doctoral work in reinforcement learning itself, where I developed deep reinforcement learning methods for UAV autonomous navigation. After years inside the training loop, I now work on the systems that run it at scale.
Selected Publications
view all publications on Google Scholar →-
2026
Conduit: An Experience Data Plane for Distributed Reinforcement Learning
@article{zhang2026conduit, title = {Conduit: An Experience Data Plane for Distributed Reinforcement Learning}, author = {Zhang, Sitong and Shi, Tuo and Di Francesco, Mario and Wang, Zeke and Zhao, Bo}, journal = {arXiv preprint arXiv:2609.24456}, year = {2026}, html = {https://arxiv.org/abs/2609.24456}, bibtex_show = {true}, selected = {true} } -
2026
Nereus: Adaptive Parallelism for LLM Post-Training
@article{jiang2026nereus, title = {Nereus: Adaptive Parallelism for LLM Post-Training}, author = {Jiang, Songlin and Shi, Tuo and Zhang, Sitong and Wang, Zeke and Di Francesco, Mario and Zhao, Bo}, journal = {arXiv preprint arXiv:2609.34645}, year = {2026}, html = {https://arxiv.org/abs/2609.34645}, bibtex_show = {true}, selected = {true} } -
2022
Autonomous navigation of UAV in multi-obstacle environments based on a deep reinforcement learning approach
@article{zhang2022autonomous, title = {Autonomous navigation of UAV in multi-obstacle environments based on a deep reinforcement learning approach}, author = {Zhang, Sitong and Li, Yibing and Dong, Qianhui}, journal = {Applied Soft Computing}, volume = {115}, pages = {108194}, year = {2022}, publisher = {Elsevier}, html = {https://doi.org/10.1016/j.asoc.2021.108194}, code = {https://github.com/RealZST/TD3-based_UAV_Collision_Avoidance}, bibtex_show = {true}, selected = {true}, preview = {asoc.png}, video = {https://youtu.be/1zL-srwnoZE?si=GUKcP2WIIknG30tJ}, podcast = {https://open.spotify.com/episode/0LpUkC6t0rKS1zCn9S490v?si=1b94c81991564f9e} } -
2023
A hybrid human-in-the-loop deep reinforcement learning method for UAV motion planning for long trajectories with unpredictable obstacles
@article{zhang2023hybrid,
  title = {A hybrid human-in-the-loop deep reinforcement learning method for UAV motion planning for long trajectories with unpredictable obstacles},
  author = {Zhang, Sitong and Li, Yibing and Ye, Fang and Geng, Xiaoyu and Zhou, Zitao and Shi, Tuo},
  journal = {Drones},
  volume = {7},
  number = {5},
  pages = {311},
  year = {2023},
  publisher = {MDPI},
  html = {https://doi.org/10.3390/drones7050311},
  code = {https://github.com/RealZST/DRL-based_UAV_Motion_Planning},
  bibtex_show = {true},
  selected = {true},
  preview = {drones.png},
  podcast = {https://open.spotify.com/episode/3XhLrCE2SYyKiYiZw4LDBr?si=fbacadb8a7a44721}
}